
Electronic Hydraulic Linear Axes in Annular Machine Tools
This page explains how electronic hydraulic linear axes work in a ring machine, where the servo valve ends and the axis begins, and what that means for cycle time and part quality. It is written for machine builders and process engineers who have to choose an axis drive, not just read a datasheet.
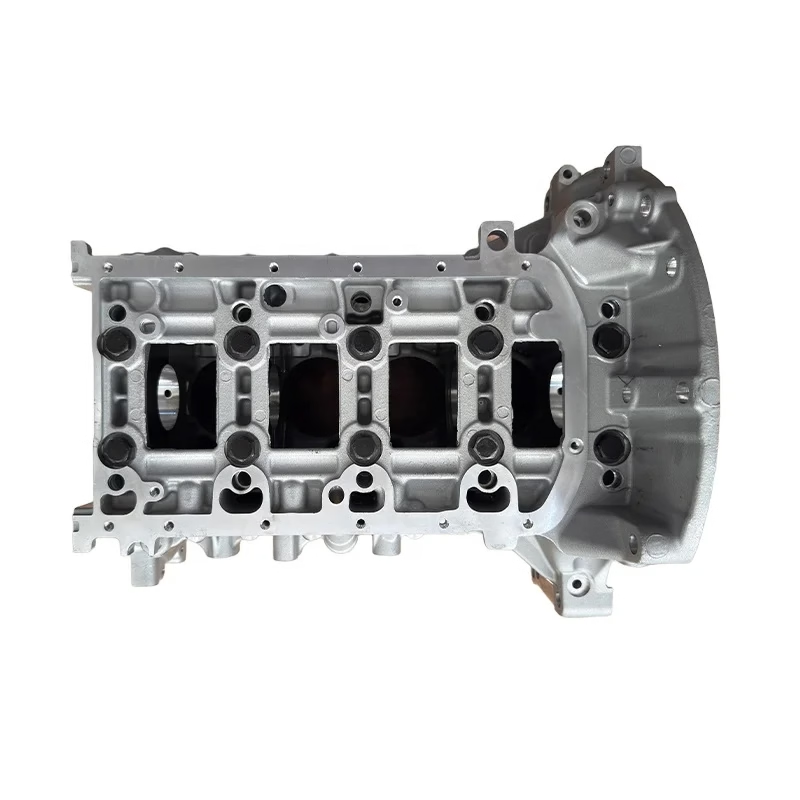
What makes an axis electronic hydraulic
A hydraulic cylinder on its own is a dumb actuator. Add a proportional or servo valve with an onboard controller, a position encoder on the slide, and a closed-loop position loop, and the same cylinder becomes an axis that can be commanded in millimeters. That is the whole idea behind electronic hydraulic linear axes.
The valve sits between the pump and the cylinder. It receives a command signal, usually ±10 V or a fieldbus setpoint, and meters flow to one side of the piston while opening the other side to tank. The onboard electronics close a spool position loop inside the valve at roughly 1 kHz. The machine control closes the outer position loop at 1–4 kHz, depending on the drive.
Two feedback loops in series sound redundant. They are not. The inner spool loop cancels valve deadband, hysteresis and oil temperature drift before those errors ever reach the slide. The outer loop then only has to correct the mechanics: friction, cutting force and column deflection.
On a ring machine this matters because the axes carry the tool head around a fixed or indexing workpiece. The slide is short, often 150–400 mm of stroke, but the moving mass is high and the force demand is uneven. A ball screw would need a large motor to hold that force at standstill.
- 1EncoderLinear scale on the slide, 0.1 μm resolution or finer.
- 2ValveServo or high-response proportional, onboard spool loop.
- 3ControllerOuter position loop, 1–4 kHz, with feedforward.
- 4Power unitPressure-compensated pump, 100–210 bar working range.
How force and speed trade off in the same axis
A hydraulic axis makes force from pressure and area, and speed from flow and area. Those two are linked by the pump, so you cannot have maximum force and maximum speed at the same instant. The valve splits the available flow between the two cylinder chambers, and the pressure difference across the piston creates the force.
In a typical ring machine axis, the bore is 40–80 mm. At 140 bar that gives roughly 18–70 kN of thrust. Increase the bore and force rises with the square of diameter, but the same valve now accelerates more oil, so bandwidth drops. This is the first trade a machine builder has to settle.
Acceleration is the other half. A slide that reaches 1 g needs the valve to fill the chamber fast enough to build pressure before the tool touches the part. Undersized valves show up as a soft ramp at the start of every cut, which leaves a witness mark on the first 0.2–0.5 mm of the pass.
The practical fix is usually not a bigger valve. It is a smaller moving mass: lighter tool head, shorter stroke, or an accumulator close to the manifold so the valve does not have to draw flow through 3 m of hose.
- 1High force, low speedLarge bore, low pump flow, heavy cut or forming pass.
- 2Low force, high speedSmall bore, high flow, rapid approach and retract.
- 3Both at onceNot possible from one pump without an accumulator.
Why the valve curve has to be linearized
A spool valve does not deliver flow in proportion to command. Near center the overlap makes the response flat, then it rises steeply, then it saturates. If the controller uses the raw curve, the axis feels dead at small commands and violent at large ones. The gain that works for a 0.05 mm move will overshoot on a 5 mm move.
Linearization maps the real flow curve, measured at several pressures and oil temperatures, into a correction table stored in the valve electronics. The command the controller sends is then proportional to the flow the valve actually delivers. One gain setting can cover the full stroke.
The measurement matters more than the table. A curve taken at 30 °C will be wrong at 55 °C, because oil viscosity changes leakage across the spool clearance. Good valves store two or three temperature-compensated curves and interpolate between them.
The payoff is repeatability across speed. A ring machine that runs at 200 mm/min for a finishing pass and 8,000 mm/min for rapid moves should show the same following error behavior in both. Without linearization, the finishing pass is the one that suffers.
- 1DeadbandSpool overlap; causes lost motion at reversal.
- 2HysteresisSame command gives different flow on up and down stroke.
- 3SaturationBeyond rated stroke, extra command changes nothing.
Where the accuracy actually comes from
People assume a hydraulic axis is less accurate than a ball screw. In a ring machine, the reverse is often true, because the errors come from different places. A ball screw loses accuracy through screw growth, nut wear and the compliance of a long shaft under thrust. A hydraulic axis has none of those.
What it has instead is oil stiffness. The trapped volume between valve and piston acts like a spring. A 50 mm bore with 100 mm of trapped oil on each side gives a hydraulic spring rate in the range of 2,000–6,000 N/mm at 140 bar. Double the trapped length and the stiffness halves.
So the mounting detail matters. Put the valve on the cylinder block, not on a panel 2 m away. Every extra centimeter of hose adds trapped volume and softens the axis. This is the single most common installation mistake on retrofit machines.
Thermal drift is the second limit. Oil at 40 °C versus 55 °C changes both leakage and bulk modulus. A machine that holds ±0.01 mm cold may drift to ±0.03 mm after four hours of continuous running if the power unit has no cooling. A chiller and a stable reservoir temperature are part of the axis, not an accessory.
- 1Short trapped volumeValve on the cylinder; stiffer axis, higher gain.
- 2Cooled oilHold reservoir at ±2 °C for stable positioning.
- 3Rigid mountCylinder flange bolted to a machined pad, not shimmed.
When electronic hydraulic linear axes beat a ball screw
Choose hydraulic when the axis needs high thrust at low speed, or when it has to hold a force while stationary for a long time. Forming, ring rolling, broaching and heavy clamping all fall into that group. A ball screw holding 30 kN at standstill needs a large motor and a brake, and it wears while it holds.
Choose a ball screw or a linear motor when the axis is light, fast and mostly unloaded, or when the machine has to run in a clean room without an oil power unit. Small pick-and-place heads, optical stages and light milling on aluminum are better served by electric drives.
There is a middle ground where both work: medium force, medium speed, moderate duty. Here the decision usually comes down to infrastructure. If the plant already has a hydraulic power unit and maintenance staff who understand it, the hydraulic axis is cheaper to own. If not, the electric axis avoids a new discipline.
One more criterion is controllability during the cut. Hydraulic axes absorb shock loads through the oil, so a chipped insert or an interrupted cut produces less position disturbance than it would on a stiff ball screw. That damping is a real advantage on cast or forged surfaces.
- 1Pick hydraulicHigh holding force, shock loads, forming, hot or dirty shop.
- 2Pick electricLight load, high speed, clean room, no power unit.
- 3Either worksMedium duty; decide on existing plant infrastructure.
Hydraulic axis versus ball screw axis
Typical values for a 200–400 mm stroke ring machine slide at 140 bar.
| Criterion | Electronic hydraulic | Ball screw | What it means on the floor |
|---|---|---|---|
| Holding force | 18–70 kN at standstill | 5–15 kN with brake | Hydraulic holds load with no motor heat |
| Max speed | 1–3 m/s on short stroke | 0.5–1.2 m/s | Hydraulic wins on rapid approach |
| Position accuracy | ±0.01 mm with cooled oil | ±0.005 mm cold | Ball screw is tighter if thermally stable |
| Stiffness source | Trapped oil volume | Screw and nut | Hydraulic needs valve close to cylinder |
| Shock load behavior | Damped by oil | Transmitted to screw | Hydraulic survives interrupted cuts |
| Thermal drift | Oil temperature dependent | Screw growth dependent | Both need cooling for tight work |
| Maintenance skill | Hydraulic and servo | Mechanical and servo | Pick what your team already knows |
| Cleanliness | Oil leaks possible | Grease only | Electric wins in clean rooms |
The short verdict
If the axis must hold 20 kN or more at standstill, or absorb shock from a rough cut, choose electronic hydraulic linear axes and put the valve on the cylinder. If the axis is light, fast and runs in a clean room, choose a ball screw or linear motor instead.
Questions engineers ask next
How often does the linearization table need to be remeasured?
After any valve or cylinder replacement, and after a major oil change. In normal service, a check every 12 months is enough.
If the axis starts showing different following error at low speed versus high speed, remeasure before touching the position loop gains.
Can a hydraulic axis hold position without the pump running?
Only with a pilot-operated check valve or a blocked-center spool. Both trap oil in the cylinder and hold the load mechanically.
Without one of those, the axis will creep as soon as supply pressure drops. For a ring machine that parks under load, this is a required feature.
What oil temperature should the power unit hold?
Keep the reservoir within ±2 °C of the setpoint, typically 40–45 °C for mineral oil at ISO VG 46.
Above 55 °C, bulk modulus and leakage both change enough to shift positioning by several hundredths of a millimeter over a shift.
Why does the axis hum or buzz at standstill?
Almost always too much proportional gain in the outer position loop, or a valve with high spool overlap.
Drop the gain by 20% and see if the noise stops. If it persists, the encoder resolution or mounting stiffness is the real problem.
Is a proportional valve good enough, or do we need a servo valve?
For positioning at 0.05 mm and above, a high-response proportional valve with onboard electronics is usually enough and costs less.
Servo valves earn their price when the axis has to follow a fast contour, above roughly 20 Hz command frequency, or when following error must stay under 10 μm at speed.
How do we know the axis is losing accuracy before parts go bad?
Log following error during the finishing pass, not just at the end of the move. A slow rise over weeks points to oil temperature or valve wear.
Check the difference between commanded and measured position at reversal. Growing lost motion means spool wear or air in the cylinder.
Send us the axis and housing drawings
We machine hydraulic manifolds, valve blocks, cylinder housings and ring machine fixtures to ±0.005 mm, with 100% inspection before shipment. Upload your files and we return a quotation with free DFM analysis within 12 hours.
12-hour quote100% inspection±0.005 mmNo minimum order
More machining notes
We publish setup notes, tooling trials and inspection data from the factory floor.











